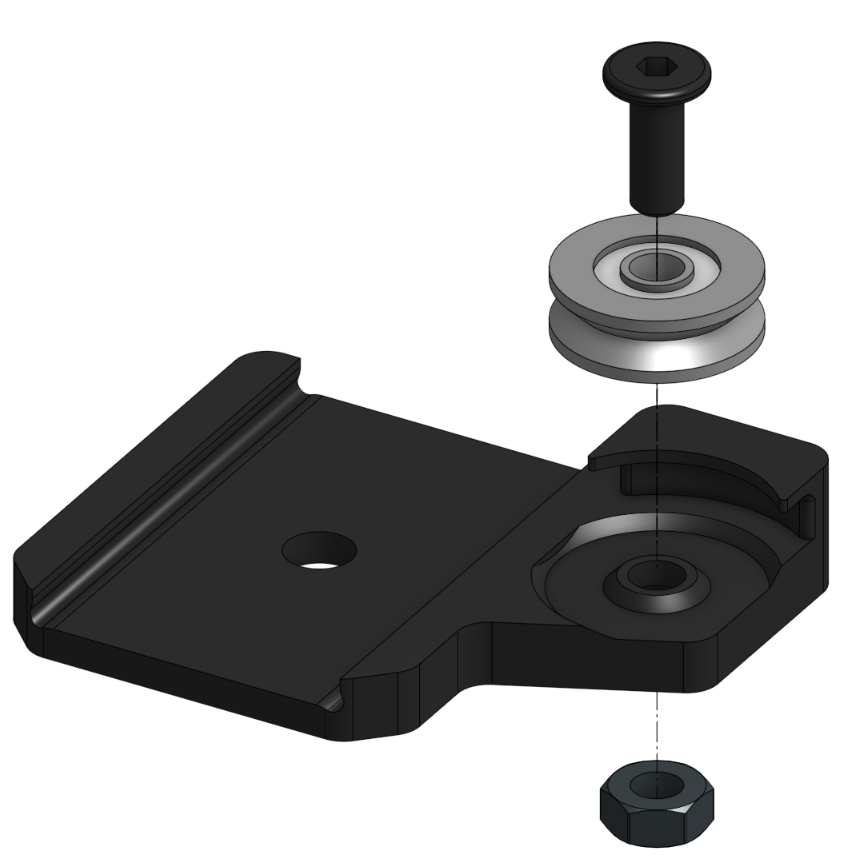
This documents the design of a linear actuator for robotics applications. The primary characteristics are low cost, light weight, telescoping actuation (the actuator extends its footprint) and high speed. The base for the actuator is stacking together Misumi SARXXX drawer slides with custom hardware to use rope to perform actuation. The use of Misumi slides is advantageous due to their low cost in large quantities and easy availability.
The specific goals of this optimization of existing insert designs is as follows
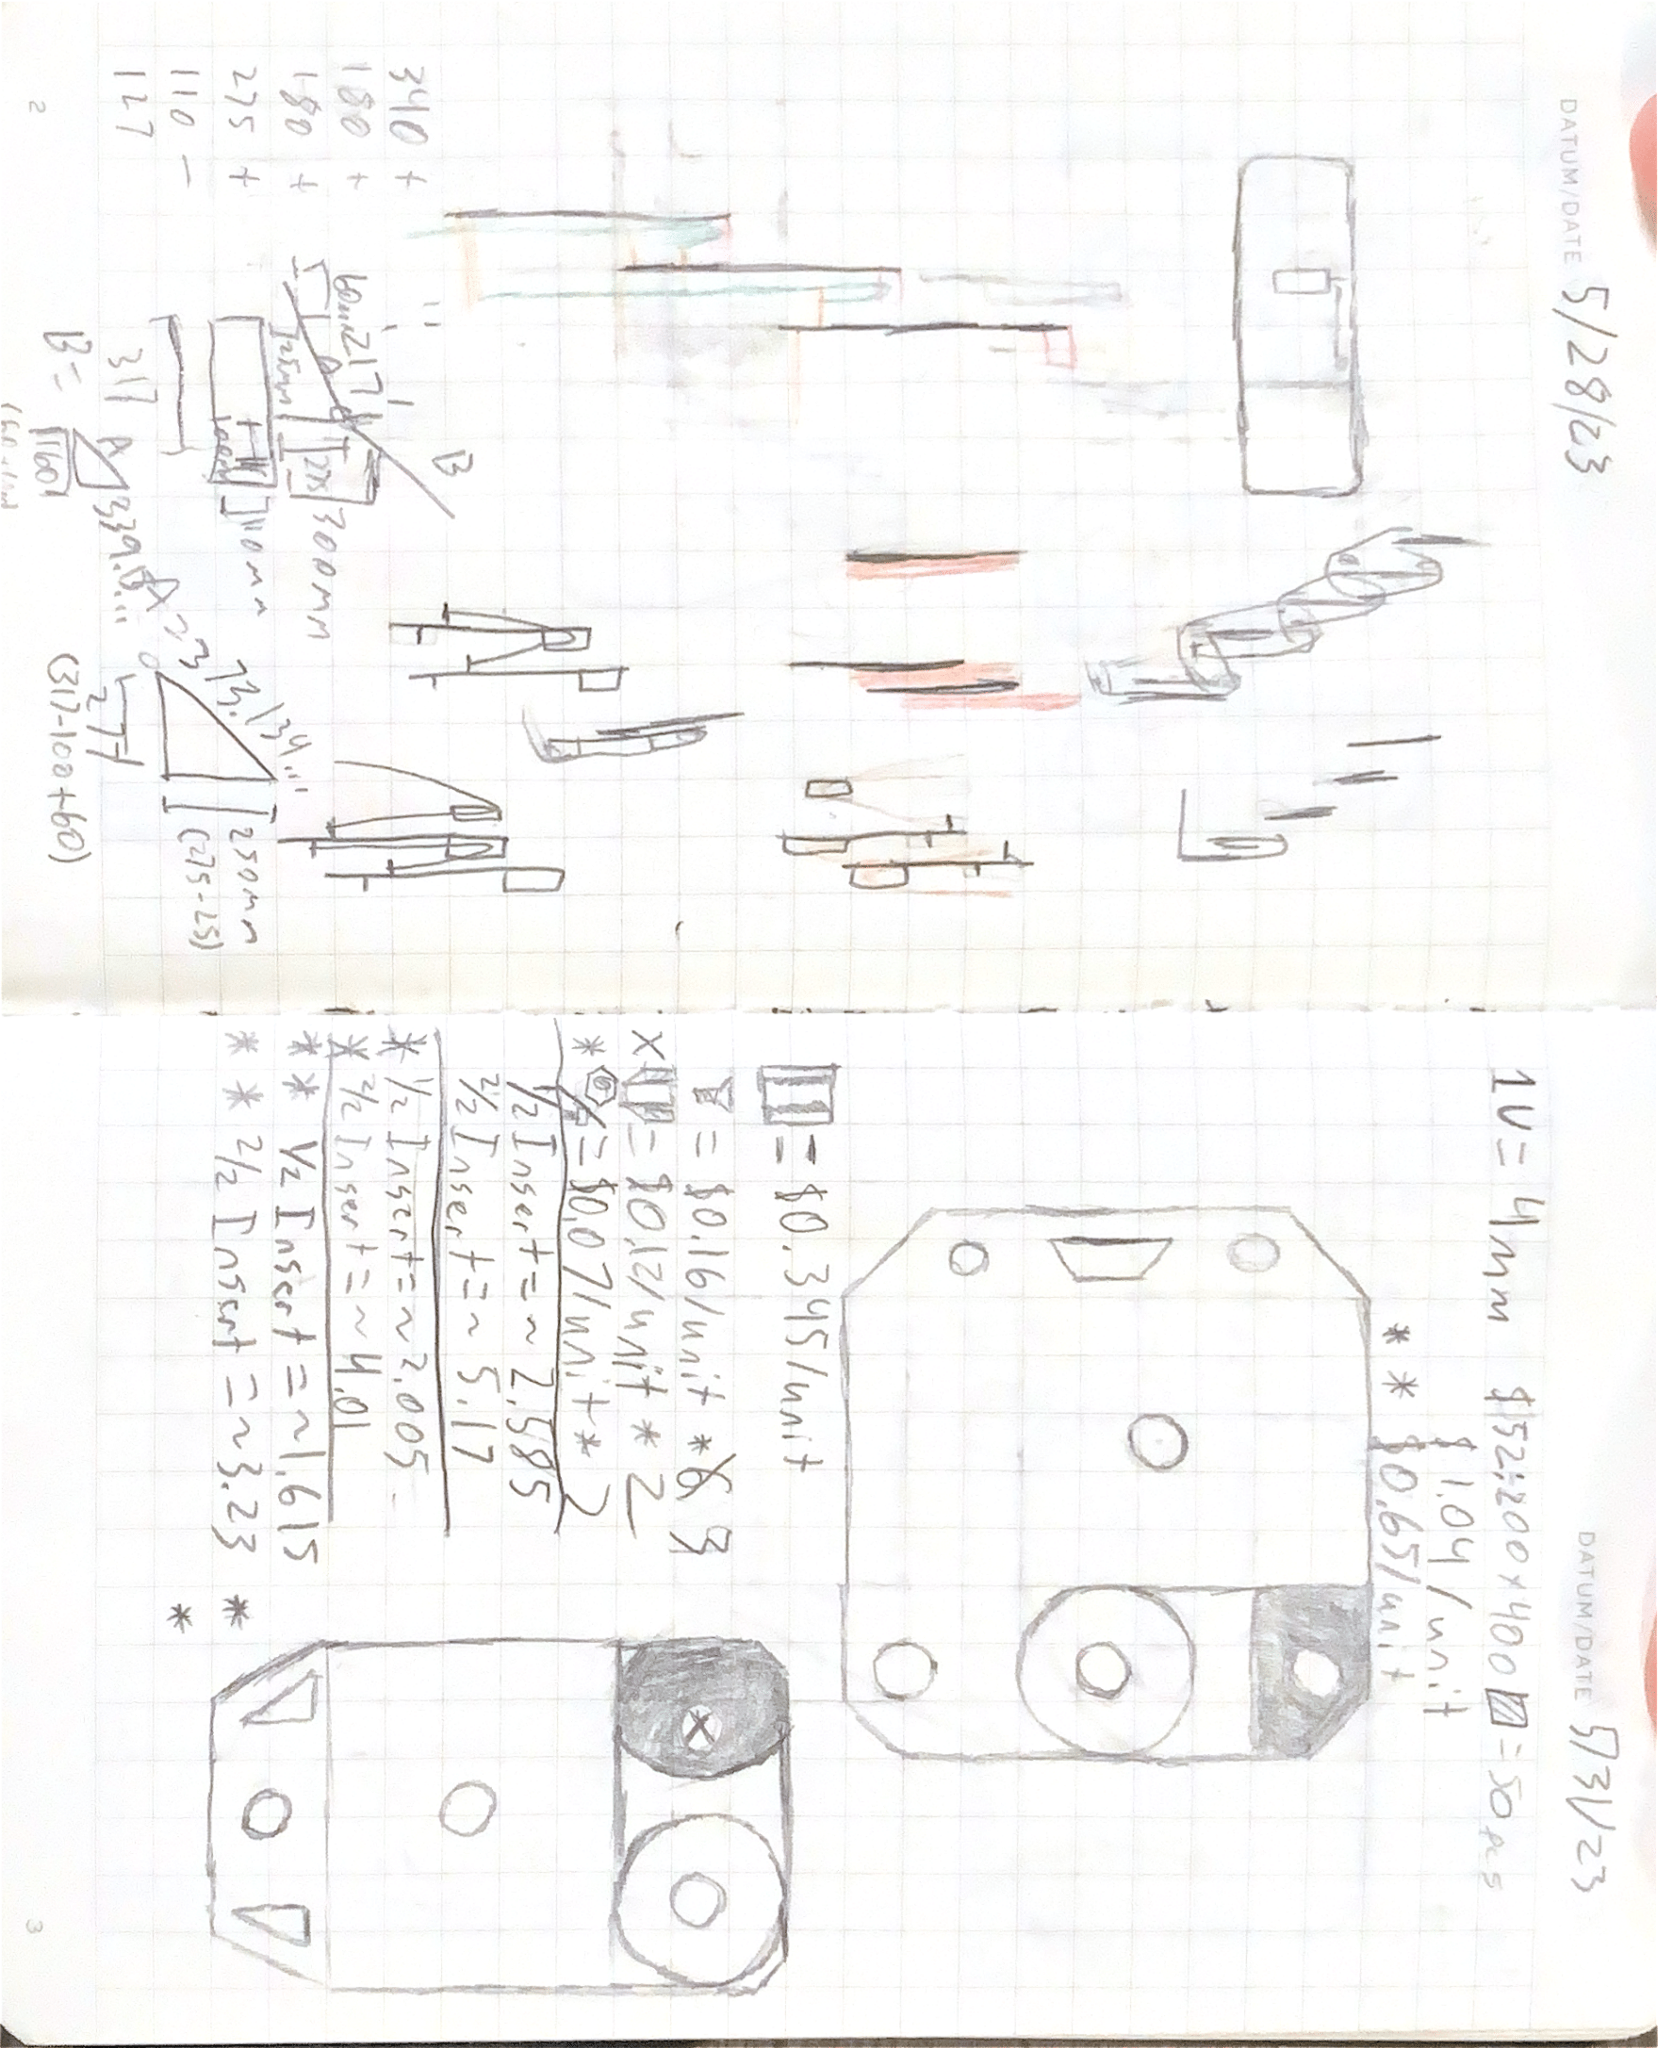
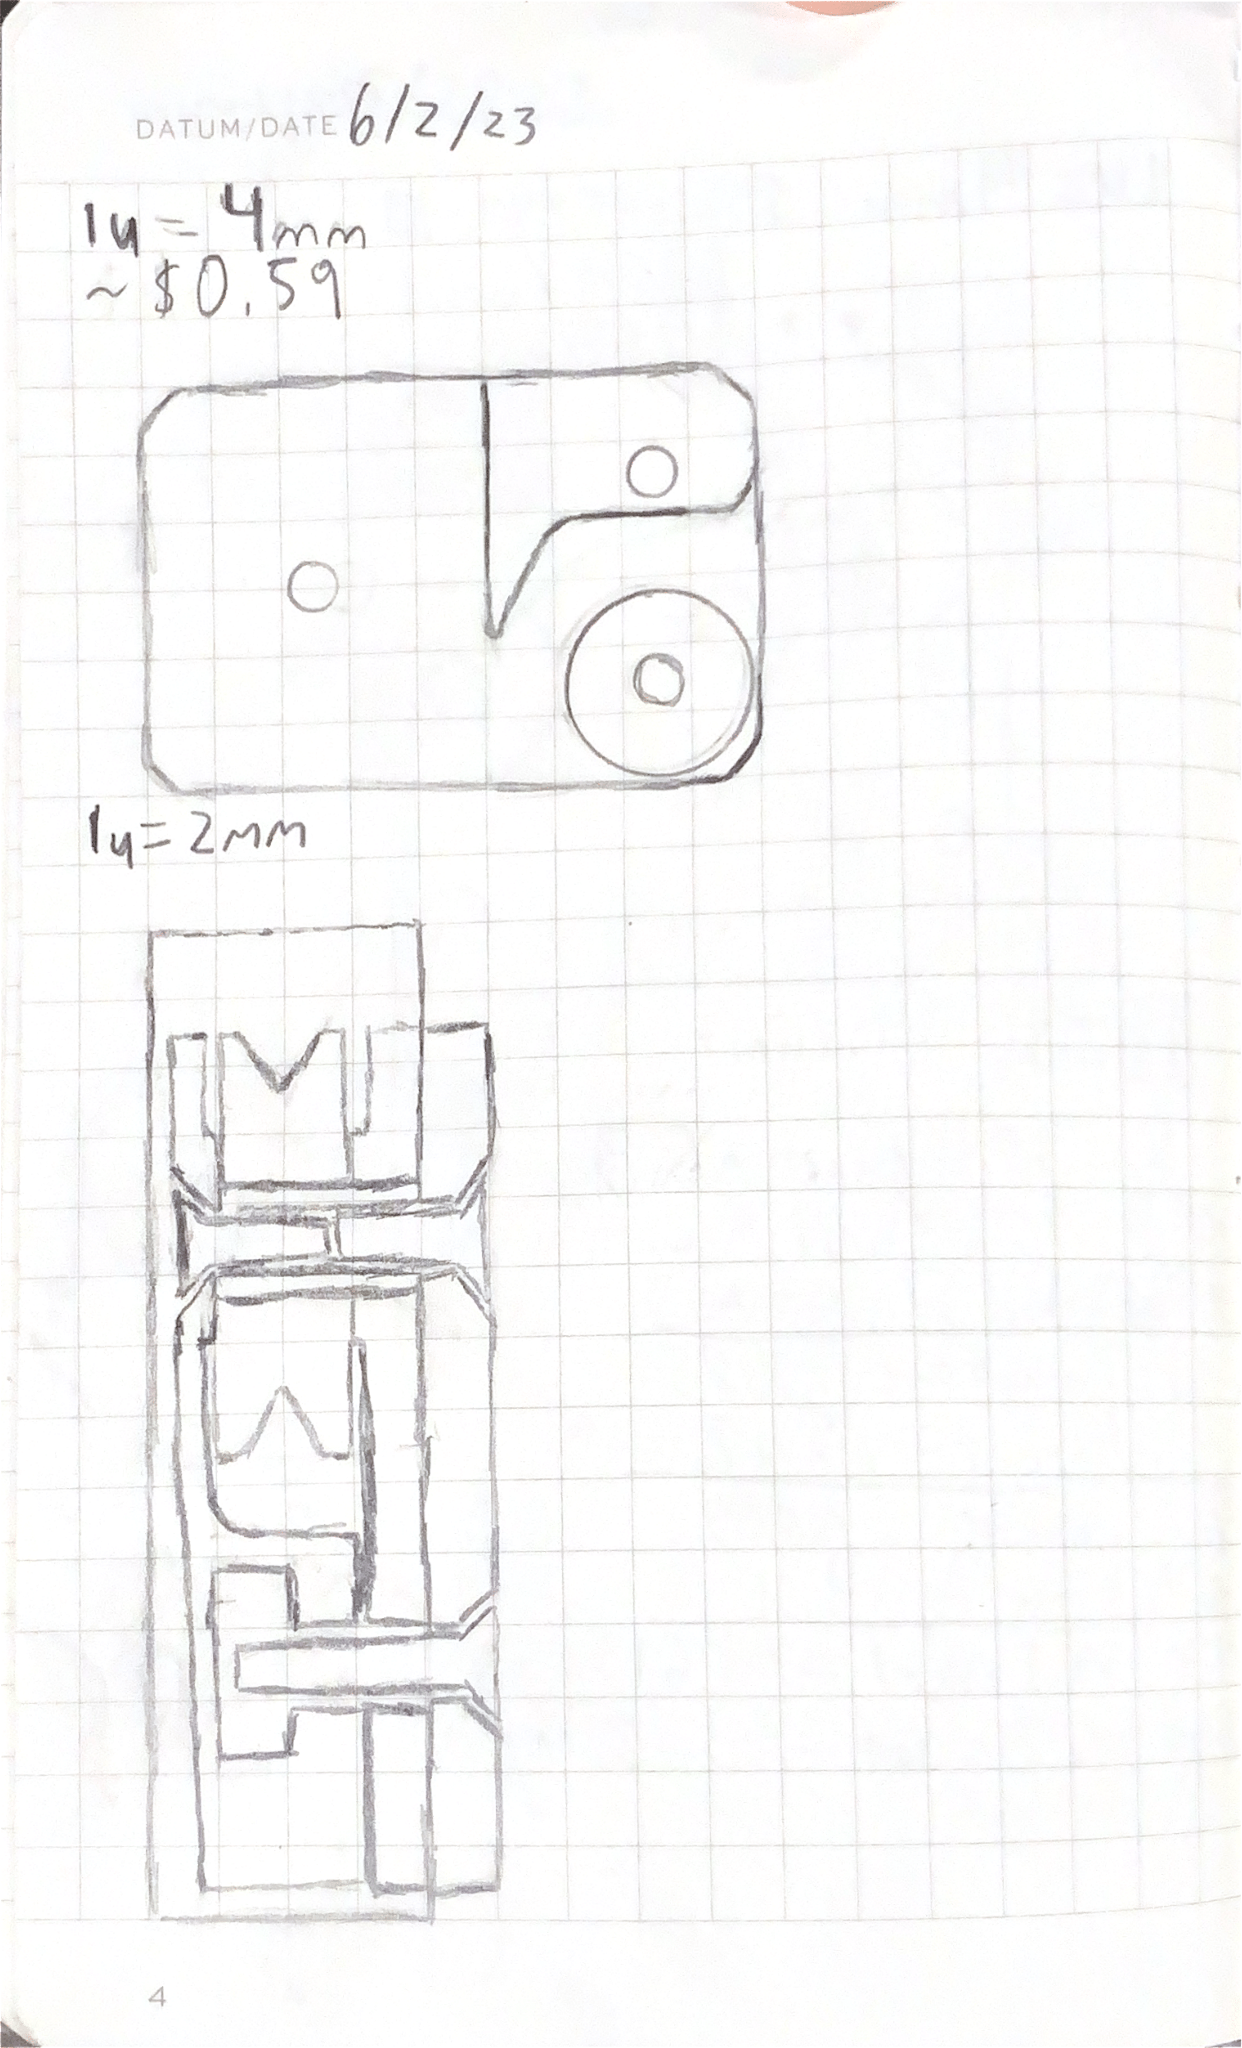
On a vacation initial mockups were sketched, prices were estimated, and general space constraints were evaluated in a initial CAD mockup.
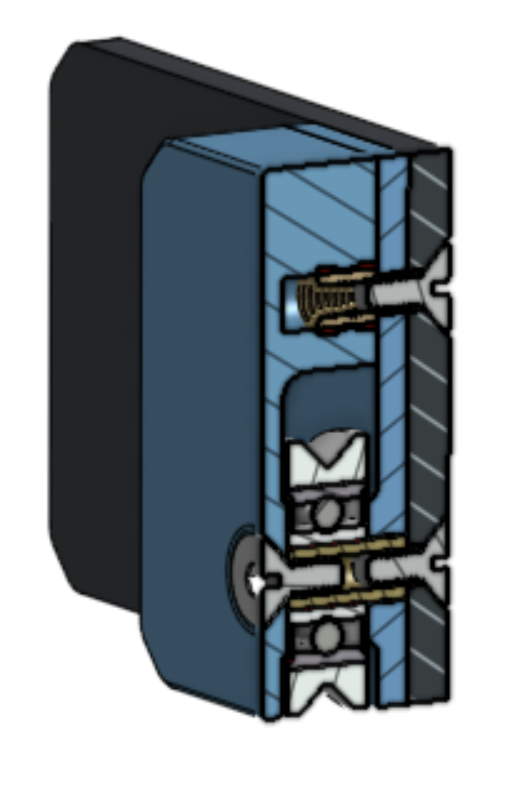
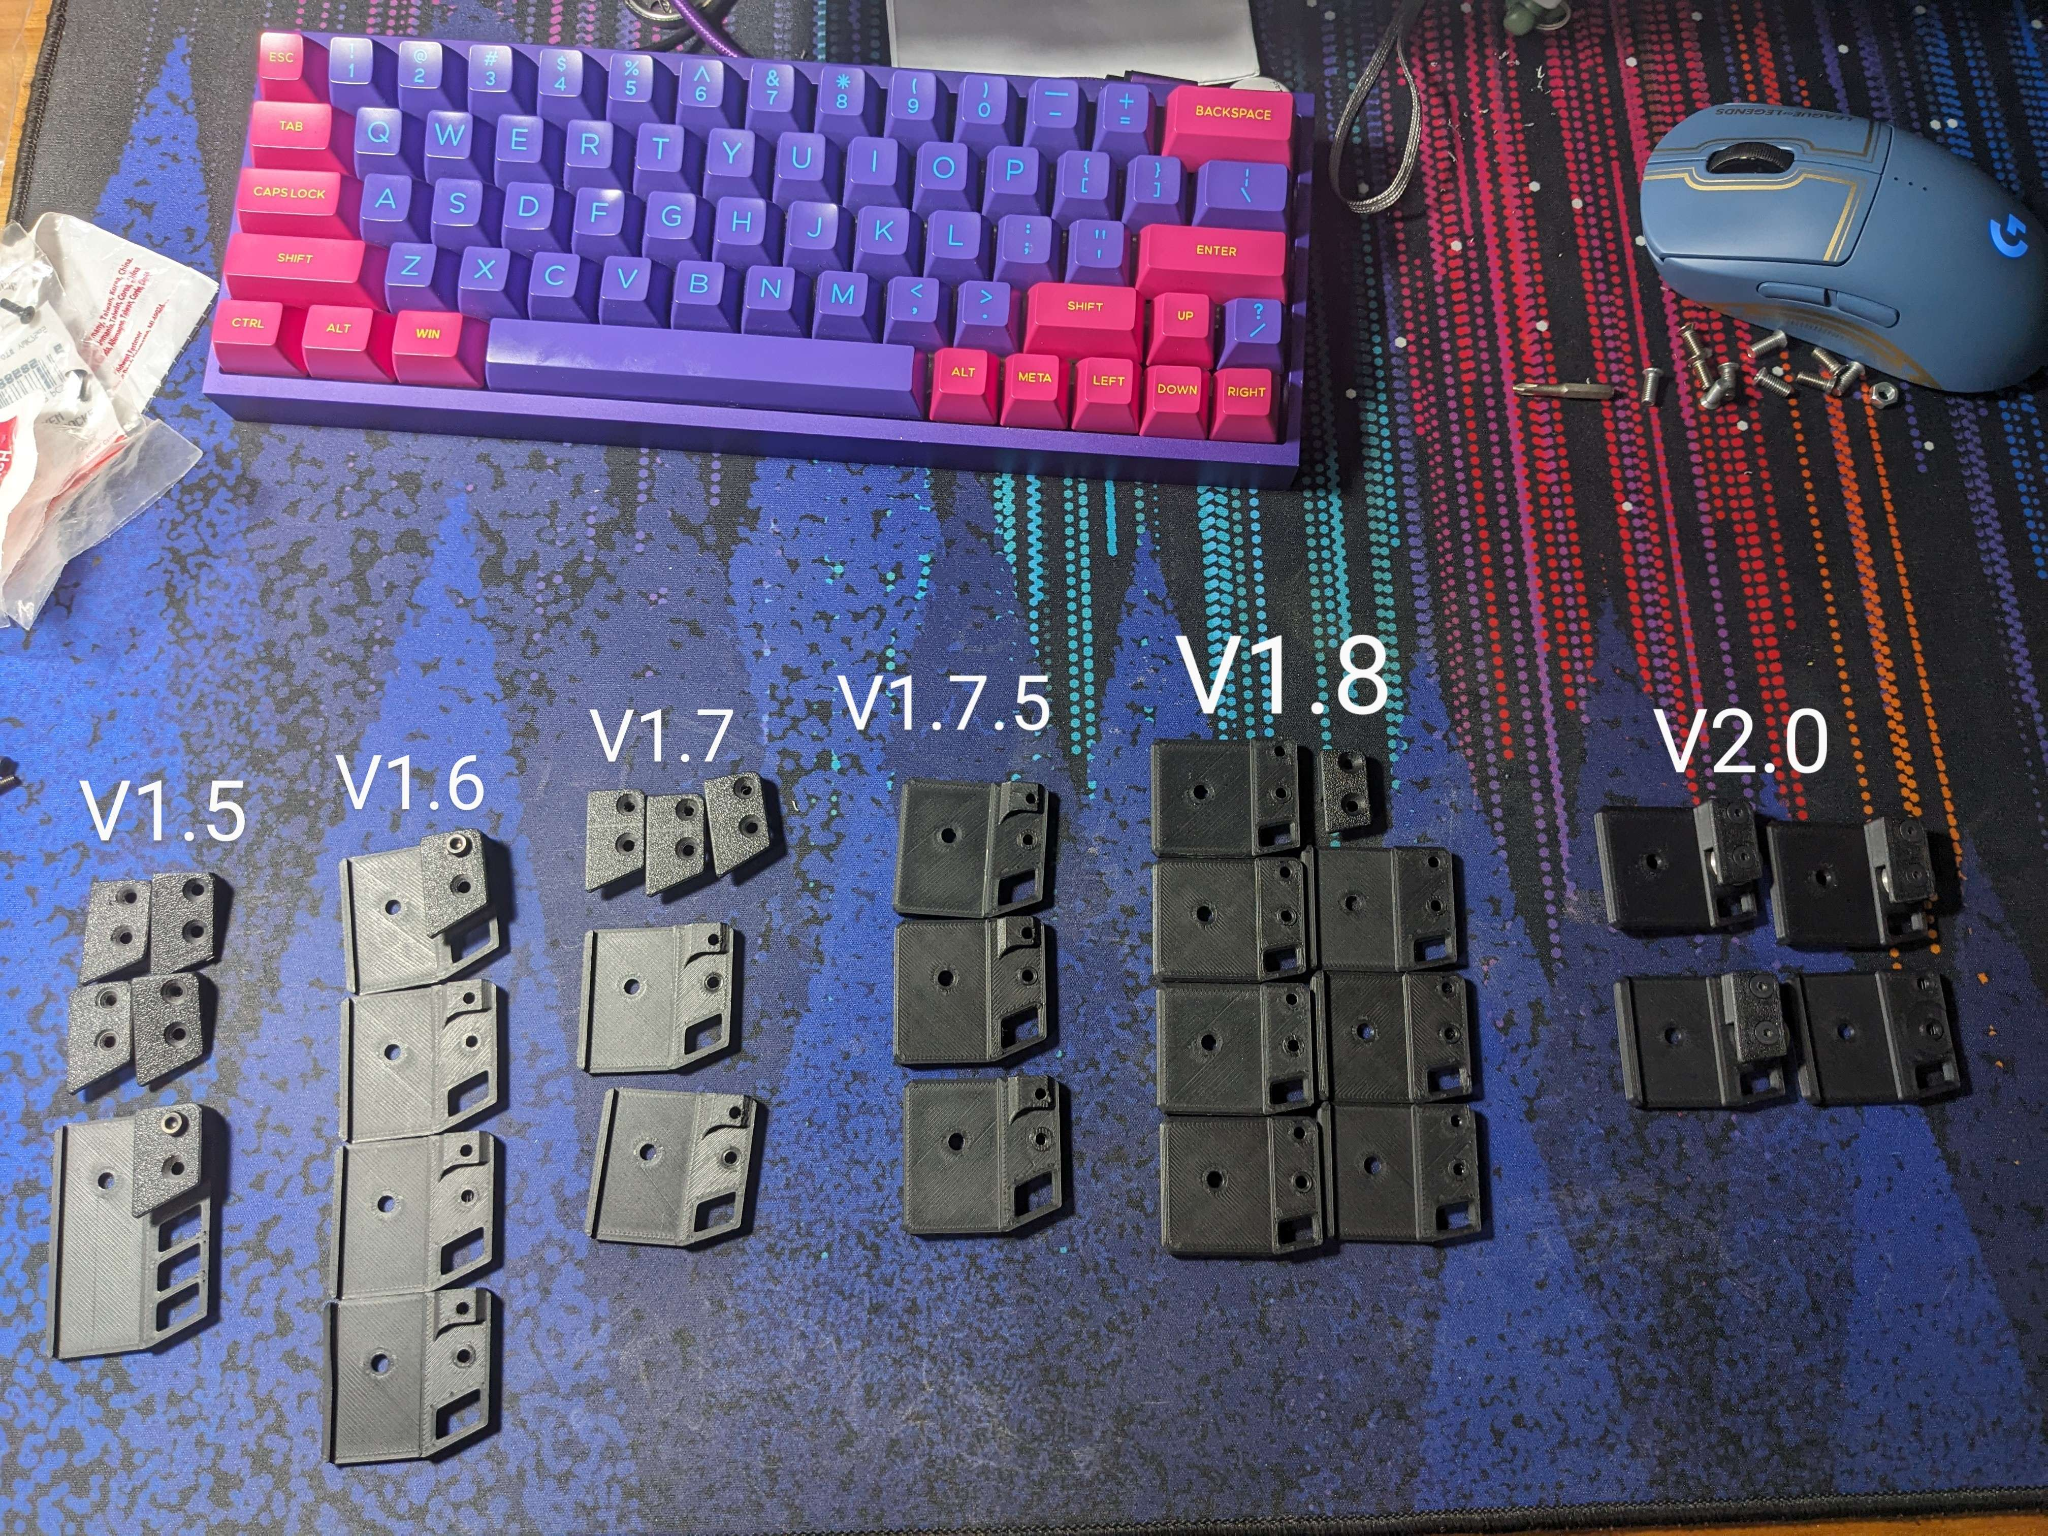
The design was then iterated in PLA to adjust tolerances, rope retention, and durability. Some versions are seen here.
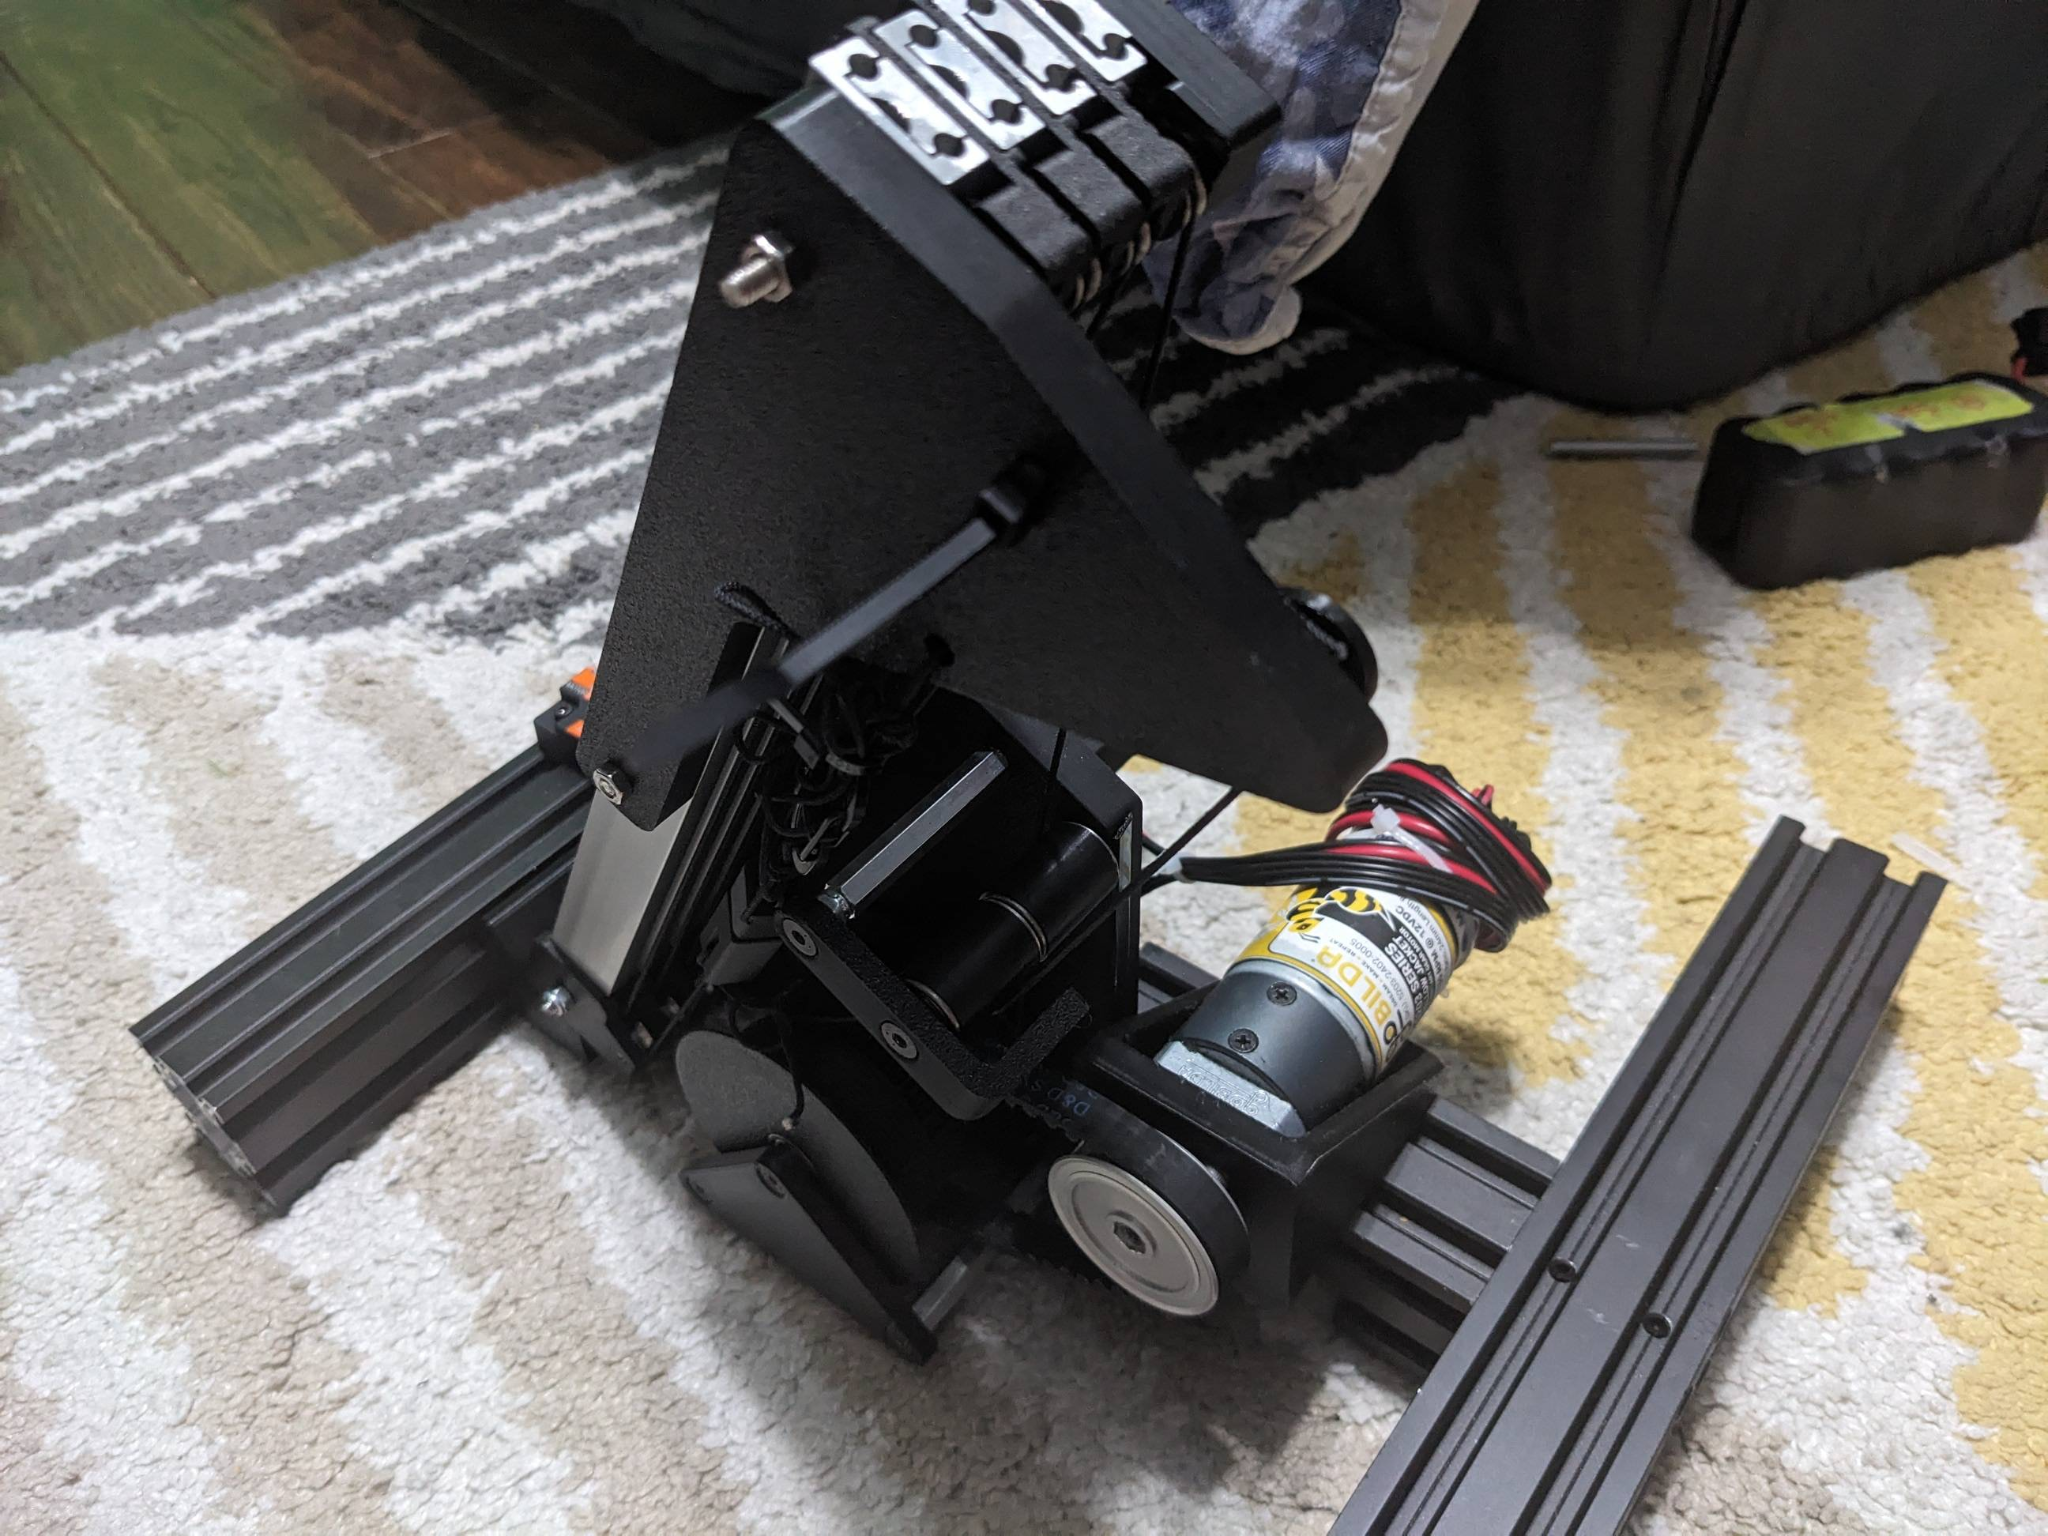
In order to validate the design could handle the target speeds and loads before assembling it into a robot a automated testing stand was made. This stand ran expected lifetime length tests on the slides in a matter of days, and also helped characterize the electrical, mechanical, and controls behavior of the entire system.
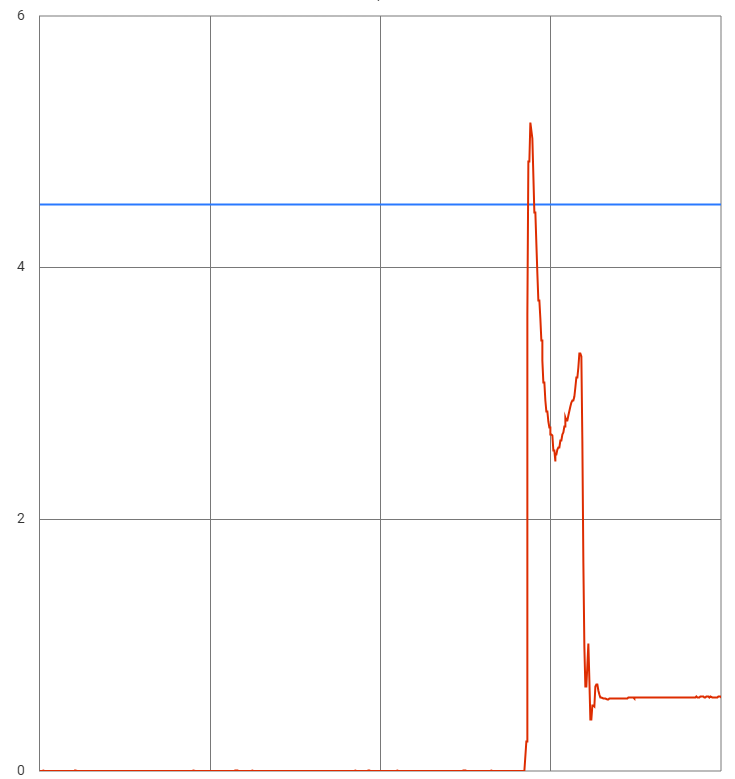
Plot shows current draw in amps vs time for one actuation, with the target peak current draw in blue
The final design achieved a 99.6% reliability (actuations without catastrophic failure) in season use, and the design allowed two parallel actuators to keep a system working even if one failed. The total width was 10mm. It was made from Fiberon PA6-CF.